Introduction: A Fast Floor, A Faster Decision
An AMR rolls toward a dock while a cart drifts across its lane and a human steps into view. The amr controller must judge distance, intent, and time in a blink. In many sites, delays from traffic stalls and re-routes can chew up double-digit percentages of throughput—small seconds add up fast. This is where an industrial robot amr controller steps in and pulls signals together from lidar, cameras, and encoders. Technical note: it has to coordinate a real-time scheduler, a SLAM stack, and edge computing nodes without missing a safety flag. So, here’s the question: what is really blocking smooth motion—code limits, sensor blind spots, or the way we orchestrate decisions? (Look, it’s simpler than you think.)
Where do legacy controls stumble?
Hidden pain sits between systems, not just inside them. Old PLC-centric setups expect fixed paths and tidy rules. But AMRs live in moving space. They need quick re-plans, clean handoffs over CAN bus, and efficient power converters that don’t starve compute during peak loads—funny how that works, right? When the controller can’t fuse data fast, you get jitter, stops, and awkward human-machine moments. Operators feel it as “robots hesitating,” managers see it as “lost minutes,” and engineers chase it as “latency spikes.” The deeper flaw is coordination: if the control brain can’t weigh safety, path cost, and battery health at once, it drifts. That is why the next section compares how control brains differ—and how those differences show up on the floor.
New Principles, Clearer Motion: Why Today’s Controllers Win
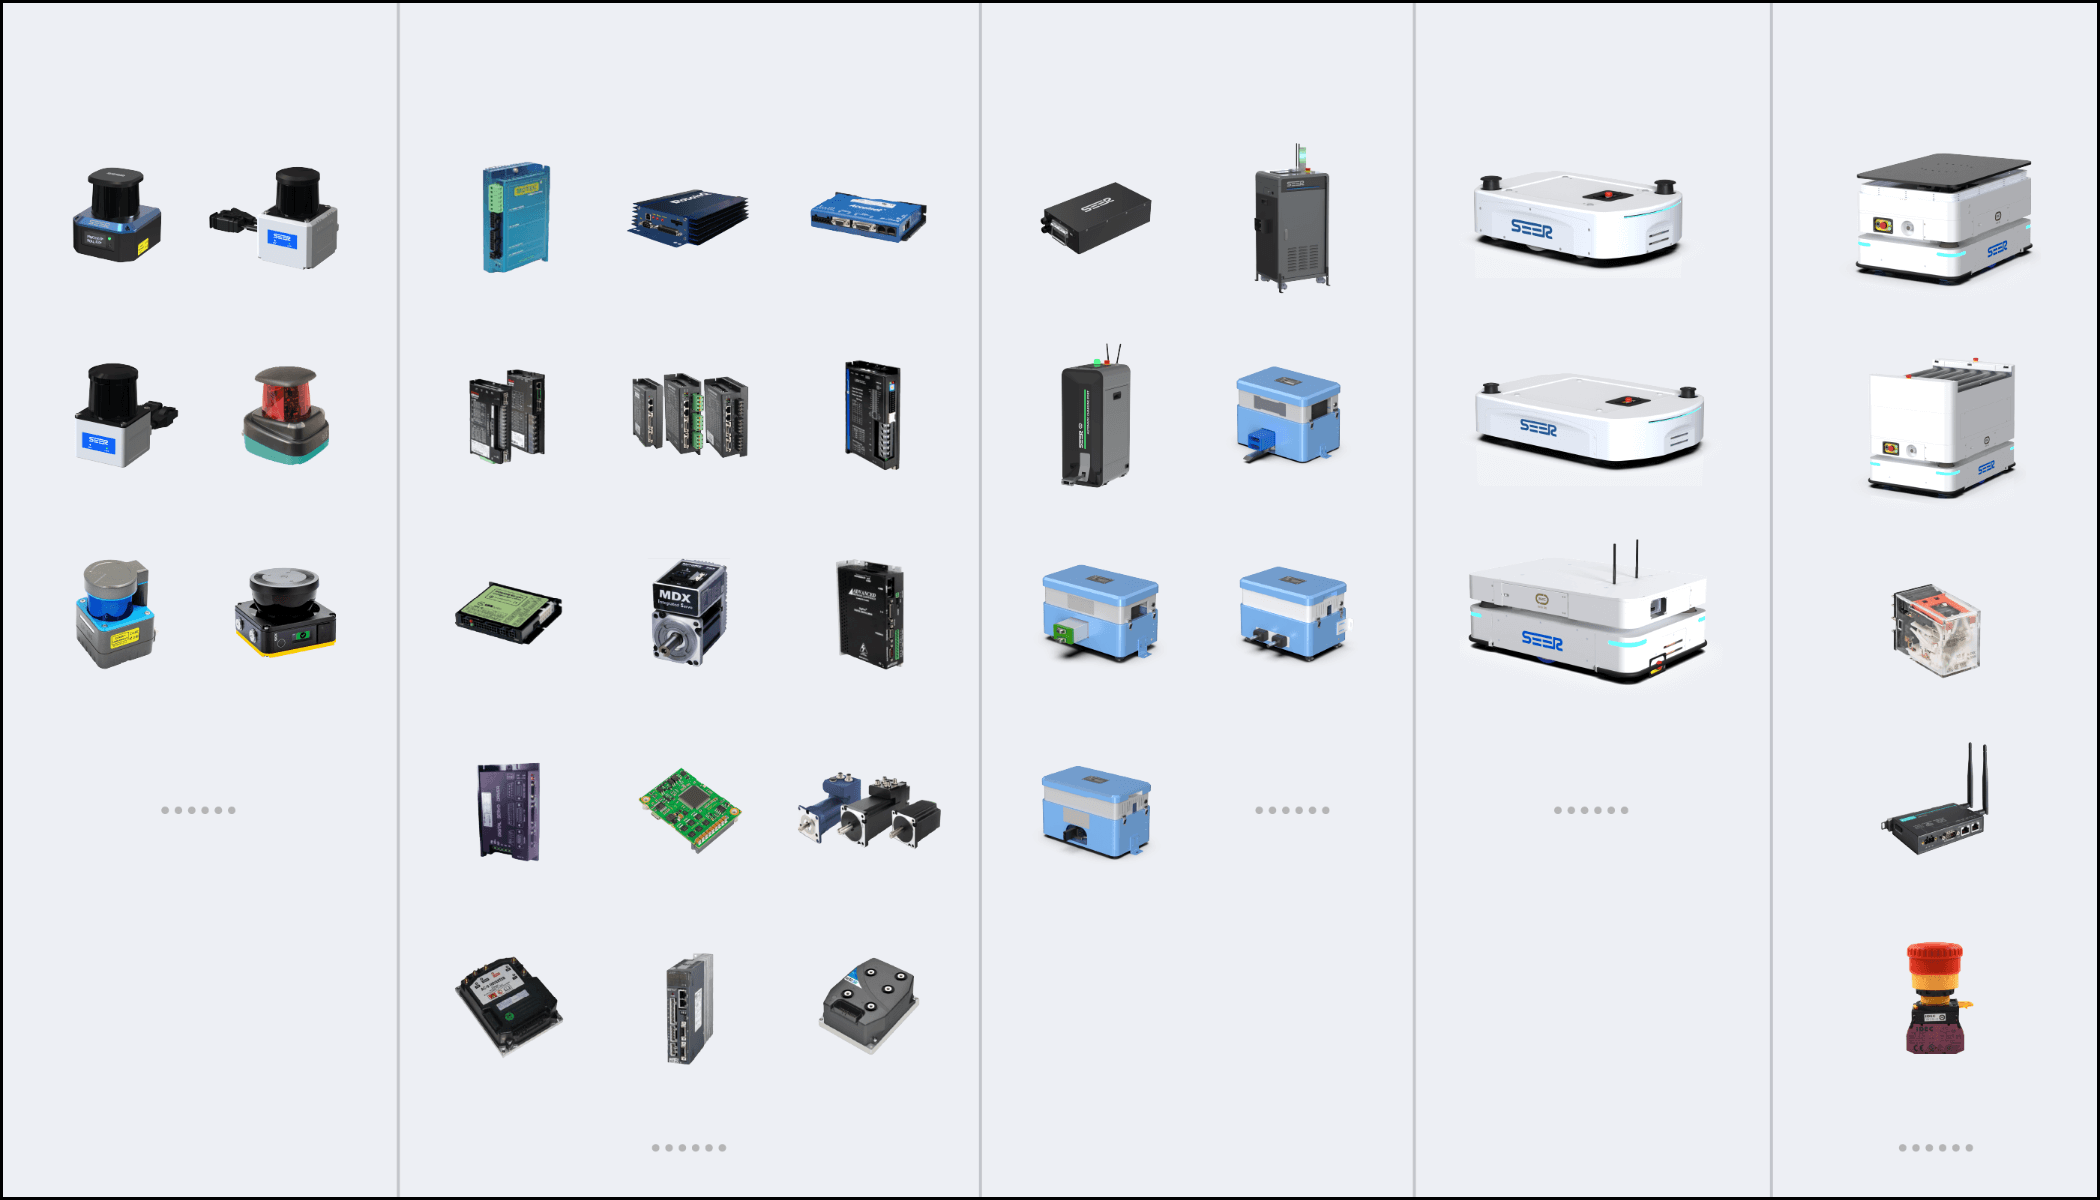
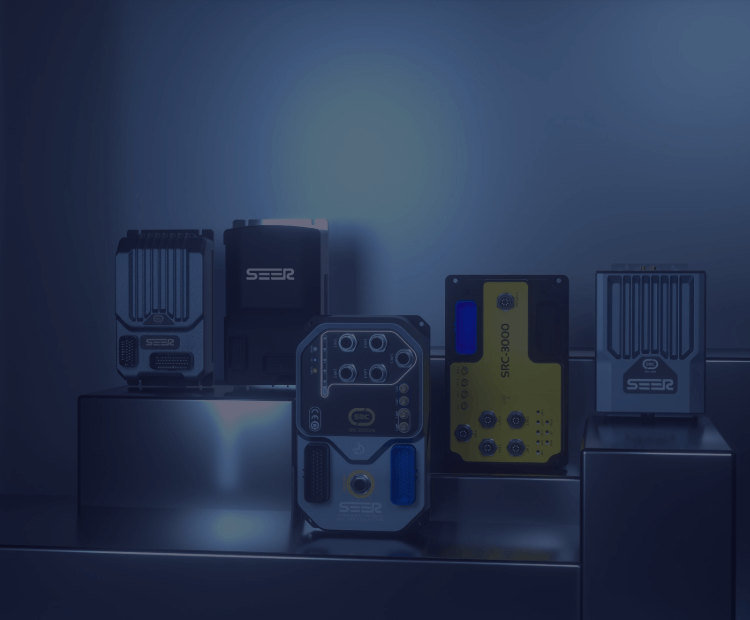
Legacy logic treats motion like a script. Modern control treats it like a conversation. A capable industrial robot amr controller balances perception and actuation in tight cycles, then chooses paths based on live cost maps. It spreads workload across edge computing nodes, so vision, obstacle checks, and kinematics don’t trip each other up. Safety stays first, but not at the expense of flow. That is the shift: from “stop or go” to “go smart.” Compared with older stacks, today’s controllers integrate sensor fusion, fleet messages, and health data in one place—less glue code, fewer blind corners. And yes, they tune for practical things like thermal limits and power converters so the wheels keep up with the brain.
What’s Next
Expect more autonomy with simpler care. Controllers will learn patterns from shift to shift, then smooth traffic before jams form—preemptive, not reactive. They will push maps and updates over secure channels, speak cleanly with MES via lightweight protocols, and trim compute waste when loads dip. In short, the control brain will feel less like a box and more like a service. Summing up the comparison: older systems freeze under change; newer ones digest change and stay moving—safer, steadier, faster. Advisory close: when choosing a controller, track three things. First, decision latency under load (sensor fusion + path re-plan time). Second, safety reaction time with humans and forklifts in close range. Third, maintainability over a year—updates, logs, and recoveries you can trust. Keep those tight, and the floor breathes easier—your team will notice.
Shared knowledge, no hype; that’s how we keep progress honest. SEER Robotics